top of page
AR Robotic Sandbox
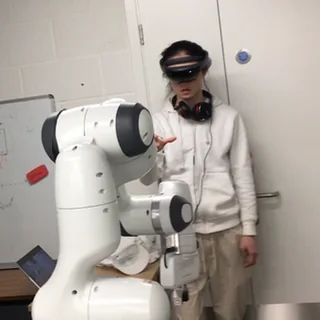
The Robotic Sandbox is an AR virtual sandbox that tells a Franka Panda robotic arm where to place bricks. The AR application records and outputs brick sequence and position to a path planning system built using ROS. Robot control was implemented through Movelt.
I was mainly involved in creating the AR environment and routing data to the Franka Panda robotic arm through a simple HTTP server.
For full project documentation & code:
This was a project of the creative engineering workshop, and is covered in the about page. Otherwise, contact me to find out more!
bottom of page